Use cases

Where Kinamics robotics already operates

Every case starts from the same problem: there is data worth having, but capturing it means exposing a person or stopping operations. These are the places where that has already changed.

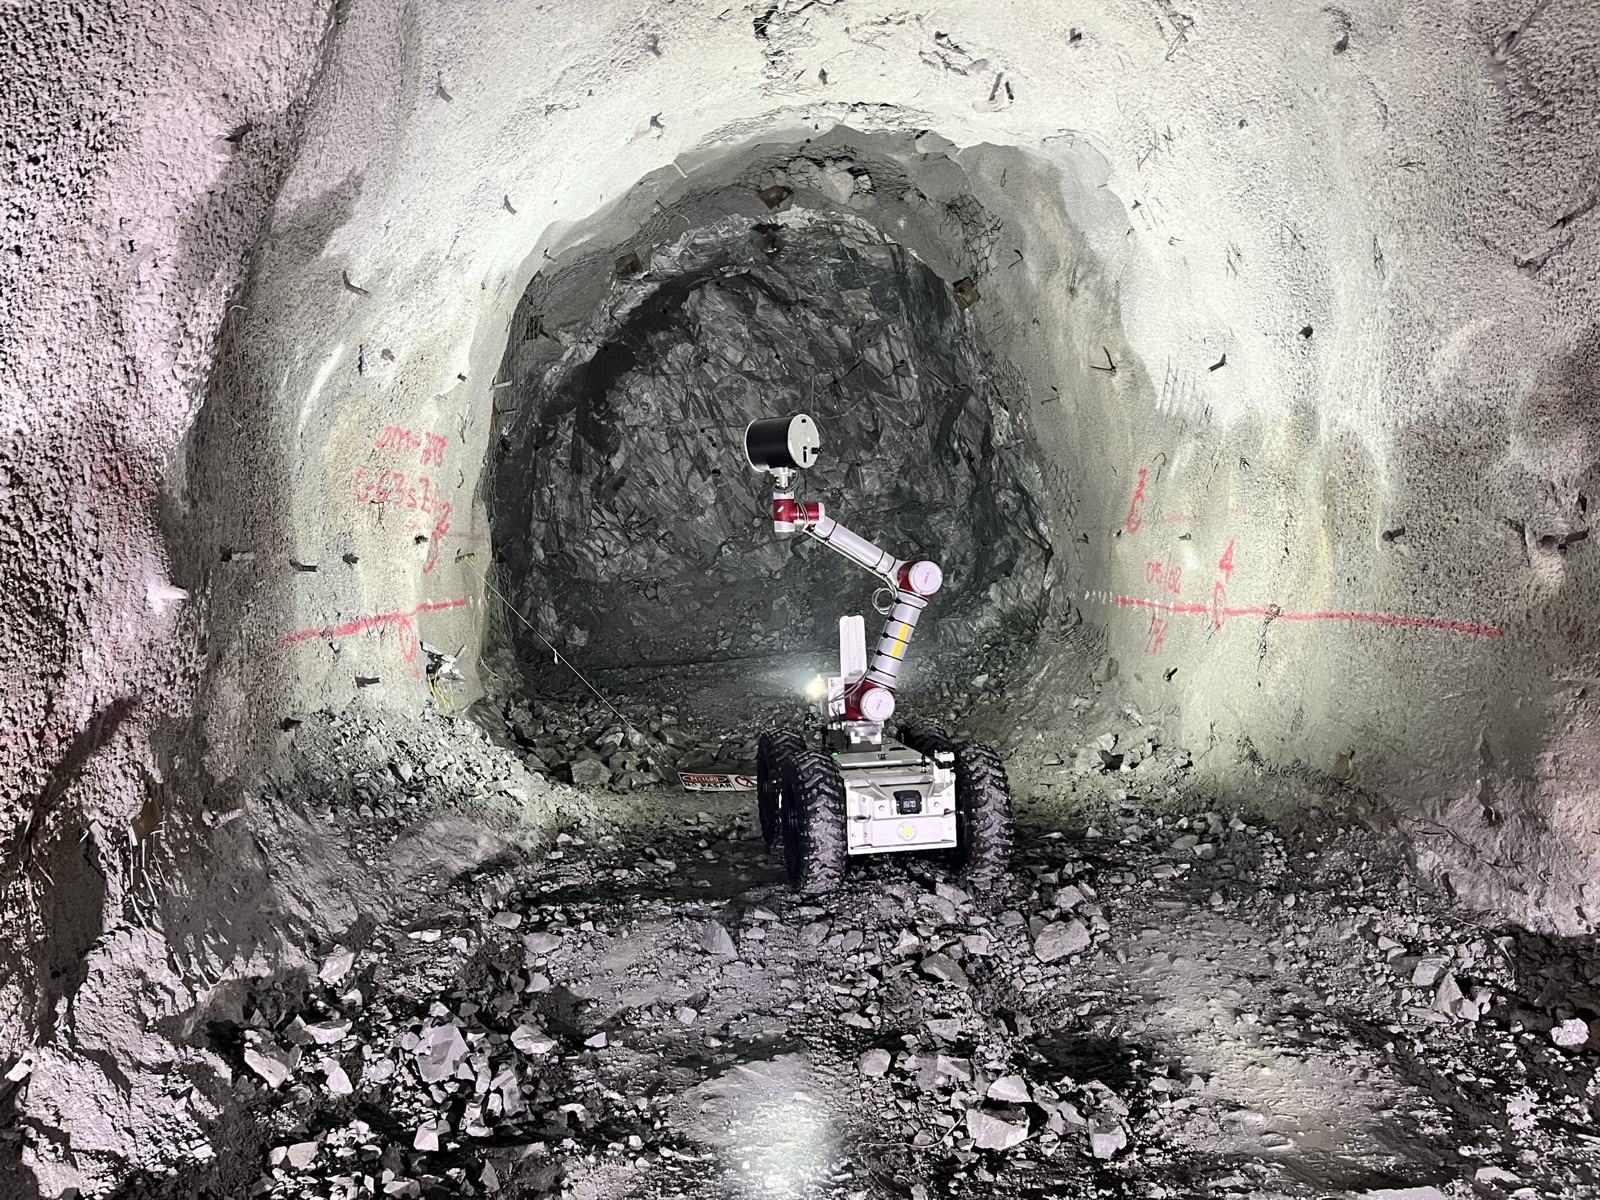
Arkytas robot capturing the face of a freshly blasted tunnel
Tunnel face

The freshly blasted face

After the blast, someone has to go in and survey the topography and geology of the face, right when the rock is still unsupported. The robot goes in instead and captures by photogrammetry from a distance: the data comes out complete and no one is exposed.

Arkytas-MU
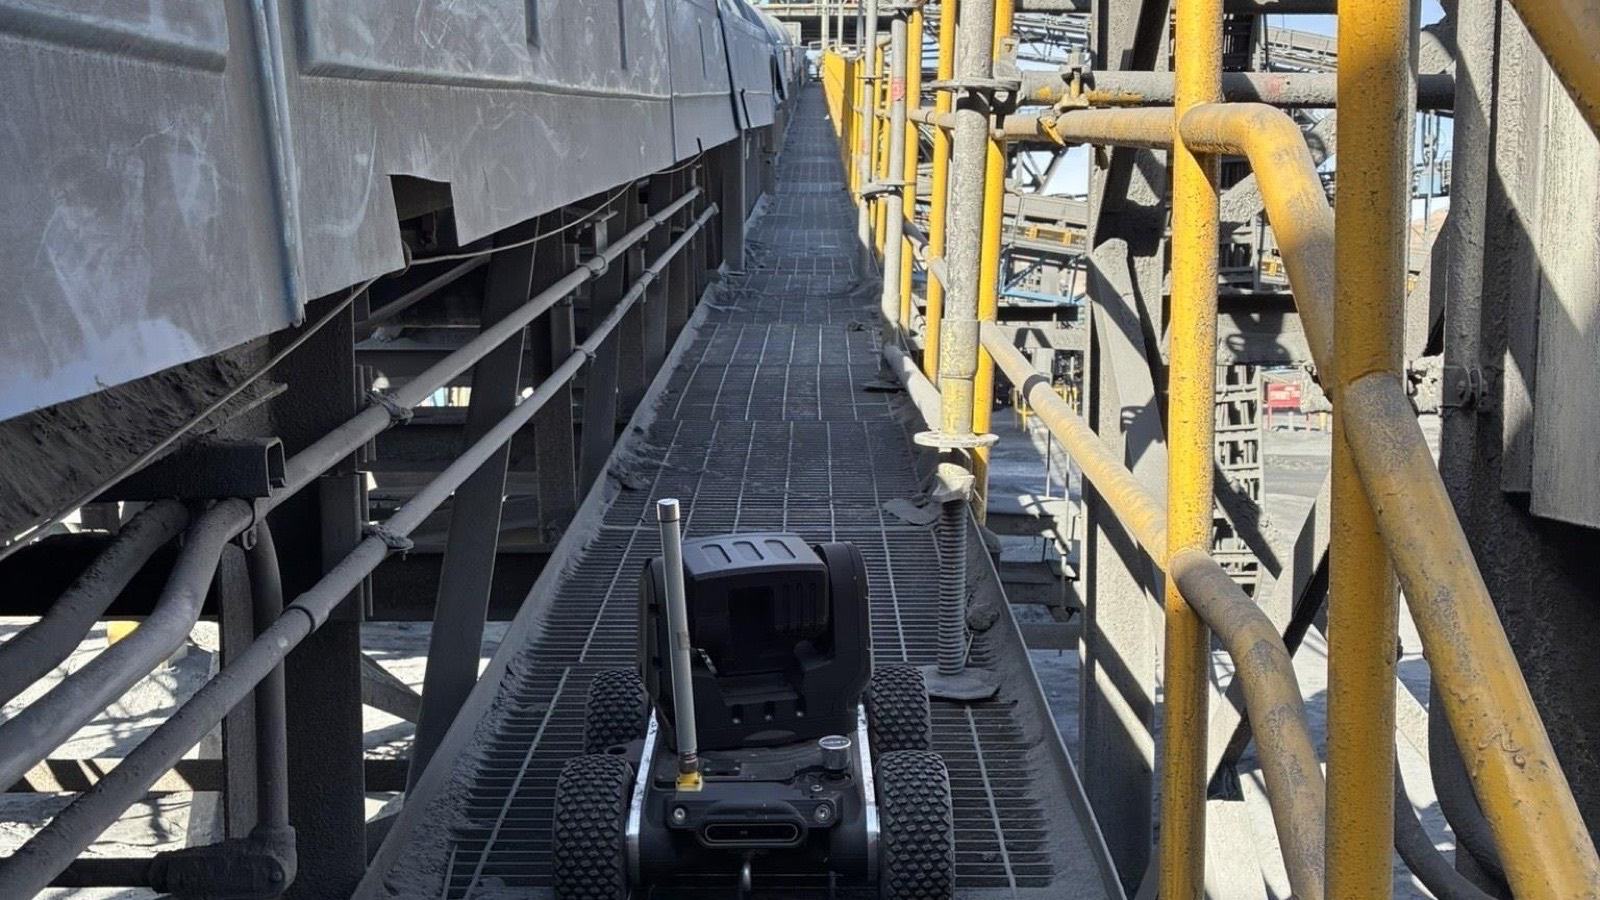
Robot inspecting the corridor of a conveyor belt at a mine site
Confined spaces

Chutes, hoppers and conveyors

Confined spaces mean permits, lockouts and a person where no one should be. The robot walks the conveyor corridor or inspects the chute with a 360° camera and night vision, commanded remotely and without stopping operations.

Arkytas-P
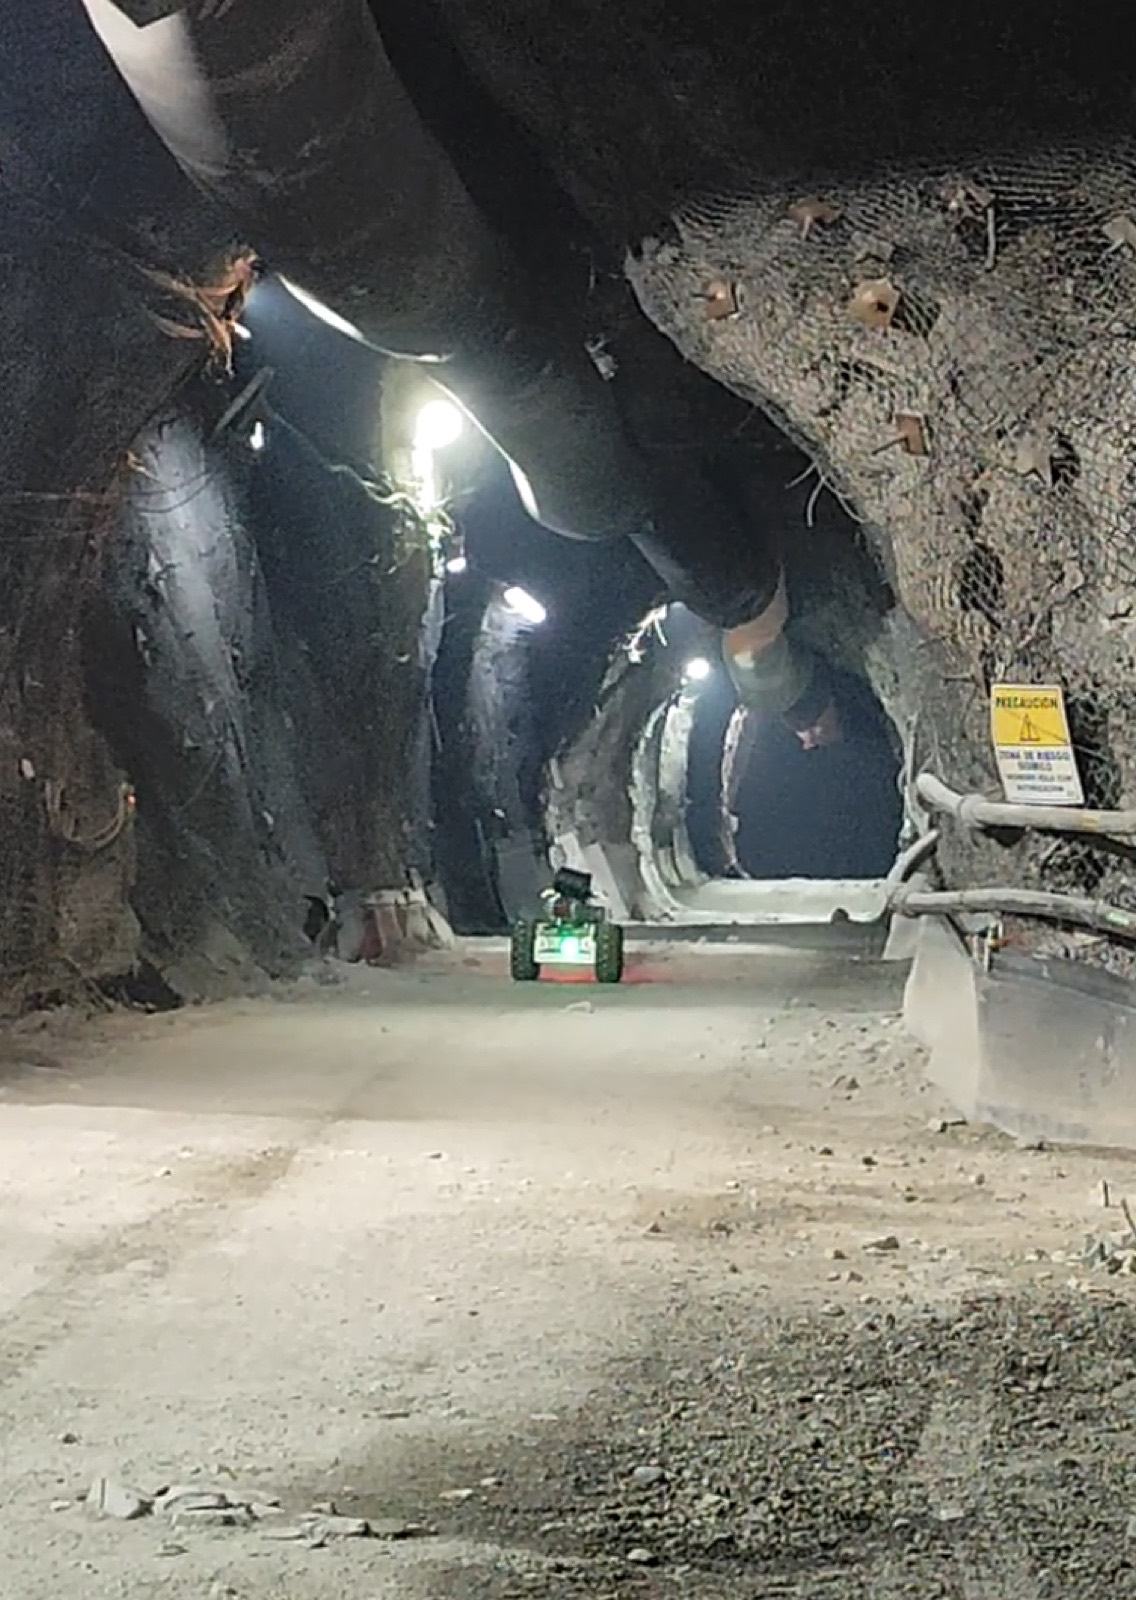
Robot moving through a tunnel under development in underground mining
Underground development

Tunnel under construction, advance after advance

Developing a tunnel needs continuous surveying: every advance, another measurement. Instead of repeating the exposure shift after shift, the robot makes the pass and delivers topography and photogrammetry consistently: same position, same criteria, every time.

Arkytas-MU
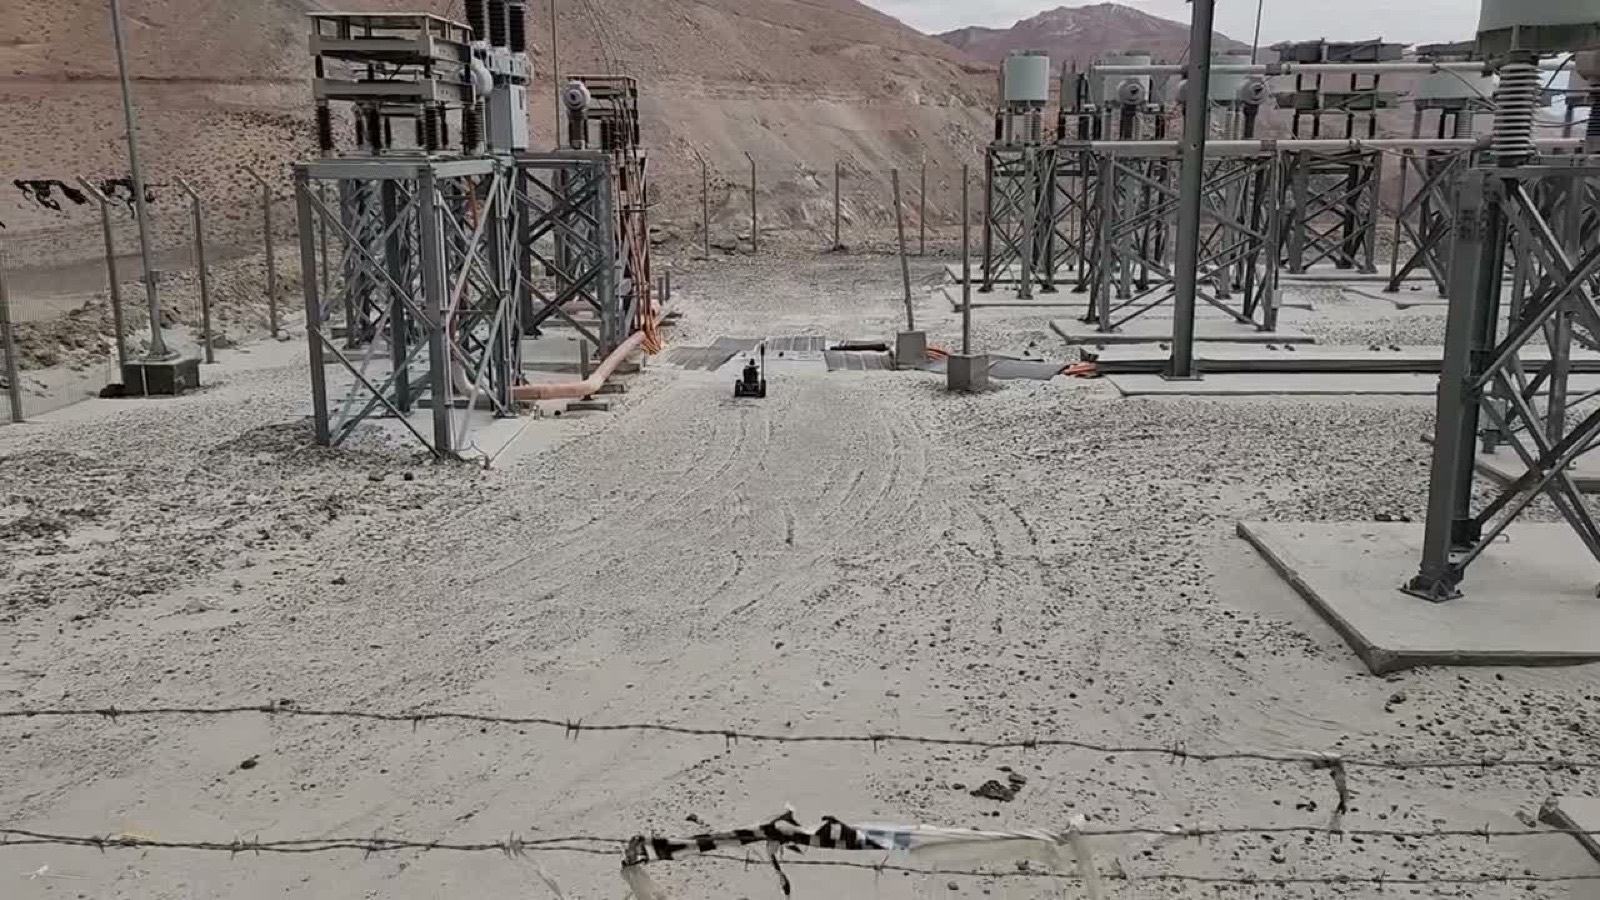
Robot moving through an electrical installation at a mine site
Energized assets

Substations and infrastructure in operation

Inspecting an energized asset usually means de-energizing it, stopping production or sending someone close to what they shouldn’t approach. The robot walks the installation and captures the asset’s condition without cutting power and without human exposure.

Robotic monitoring